Monday, November 14, 2016
Week Twelve - Monday: Beginning SolidWorks
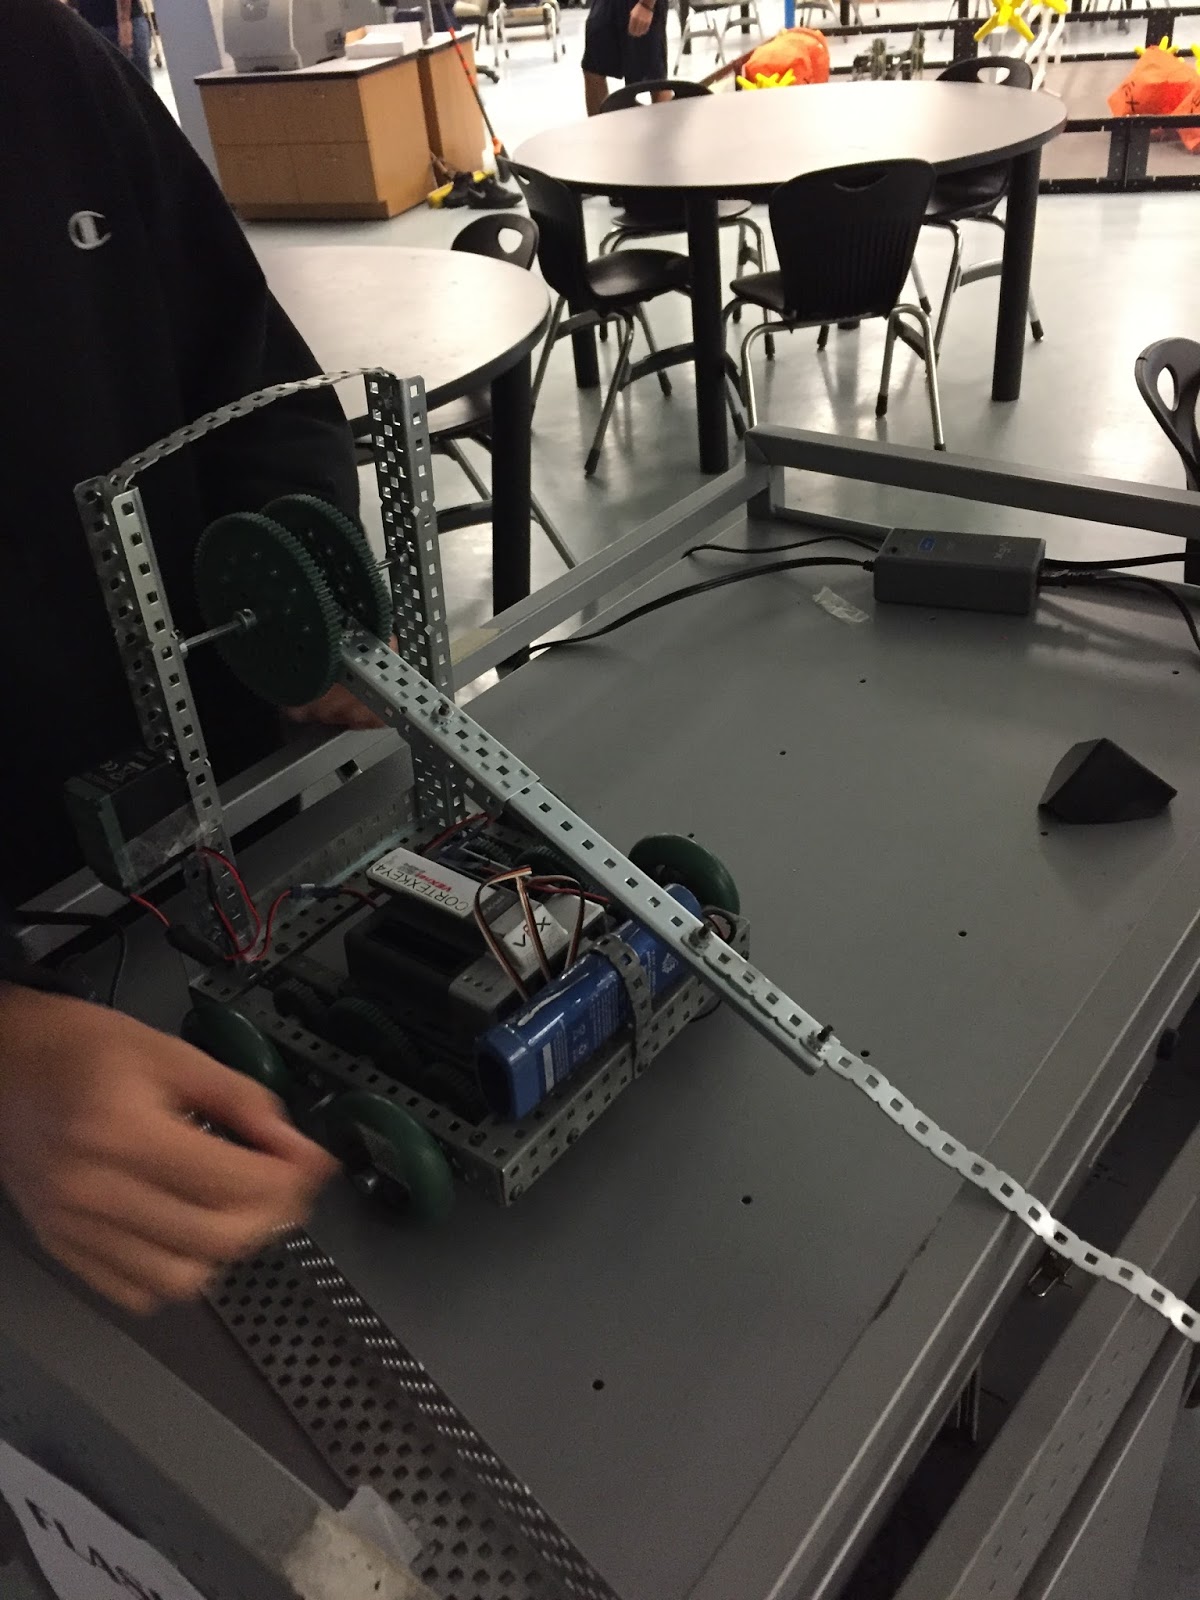
Today we completed the addition of our two new gears. The gears are now able to successfully compensate for the previously overbearing weight of the robot's arm. We also began SolidWorks, in SolidWorks we added the foundation for the arm and by tomorrow we should have successfully added all of the gears, collars, and metal components used for the arm (channels, angles, etc.)
Thursday, November 10, 2016
Week Eleven - Thursday: Foreseeing Fame
Through out this week, we used trial and error to find the most efficient design for our robot's arm. We swapped in two larger gears to compensate for the lack strength required to move the heavy arm. By next week we plan to complete the challenge and also complete SolidWorks.
Monday, November 7, 2016
Week Eleven - Monday: This Arm Ain't Big Enough for the Both of Us
To start off this week, we have concluded that the positions and size of the gears were not efficient enough, so we decided to upgrade and use bigger gears. Along with the gears, we will make the arm just a tad bit longer, so then we can raise the tetrahedron up to the top of the pipe. Our only problem here is that the arm is too heavy and when we raise the arm the bot lifts off the ground.
Friday, November 4, 2016
Week Ten - Friday: Challenge Clarification
The main gist of the challenge is to place three tetrahedrons at the top of an array of pipes. The main issue we're having right now is that our arm isn't long enough, mainly because the wheels of our robot are much tinier than last year, so we need more length on our arm. We tightened the screws and bezels around the robot.
Monday, October 31, 2016
Week Ten - Monday: Halloween Hindrances
Our robot has been giving us a few issues, and I've scientifically deduced that the cause of it is a Halloween curse. Our arm isn't long enough to reach the top of the array of pipes, a few screws popped off the robot, and the arm is moving with too much power, so we have to tone it down. Thankfully, all of these issues have simple solutions. We just have to make the arm longer, tighten the screws, and lower the amount of power on the arm's motor.
Friday, October 28, 2016
Week Nine - Friday: Arm Yourself With an Arm!
We've attached the arm to our robot and we also attached the motor to the arm. Our arm uses a series of gears to move the arm upwards by using the motor to move axles. Our design is standard and our goal is simple, use an arm to get tetrahedrons on top of an "obstacle". We hope to complete the challenge within two weeks,
Monday, October 24, 2016
Week Nine - Monday: Tetrahedron Turmoil
Today we've begun the construction of the arm meant for the completion of the tetrahedron challenge. The tetrahedron challenge involves using an arm on your robot to place tetrahedrons on a design of pipes, with various higher spots on the construction of pipes earning you a greater sum of points. This challenge is going a lot smoother than the chair challenge, now that we finally have functioning motors.
Subscribe to:
Posts (Atom)